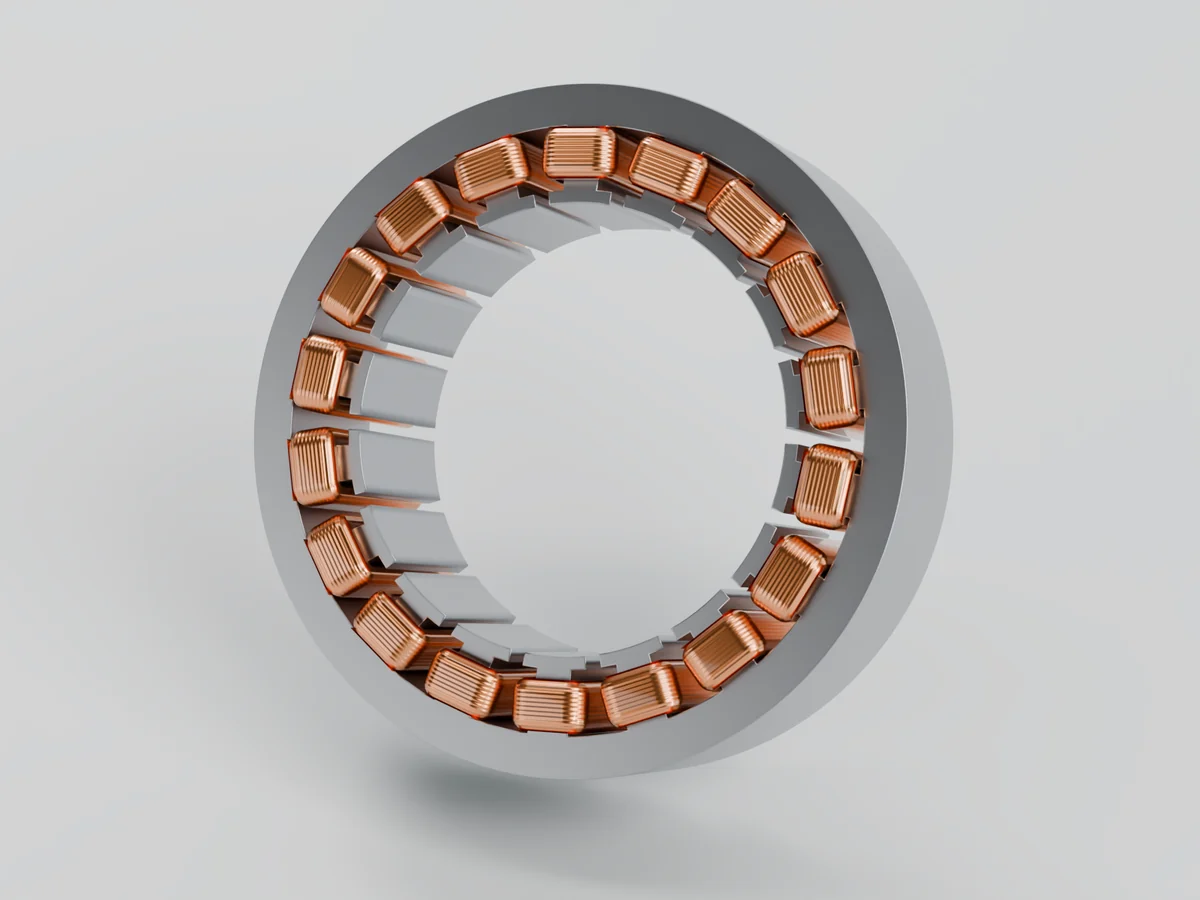
로봇마다 관절의 크기와 하중이 다릅니다. AXIVON은 관절마다 잇수와 크기를 다시 계산해 AX-P 유성기어 감속기를 설계·공급하고, 모터와 드라이브를 더한 액츄에이터 설계도 상담합니다.
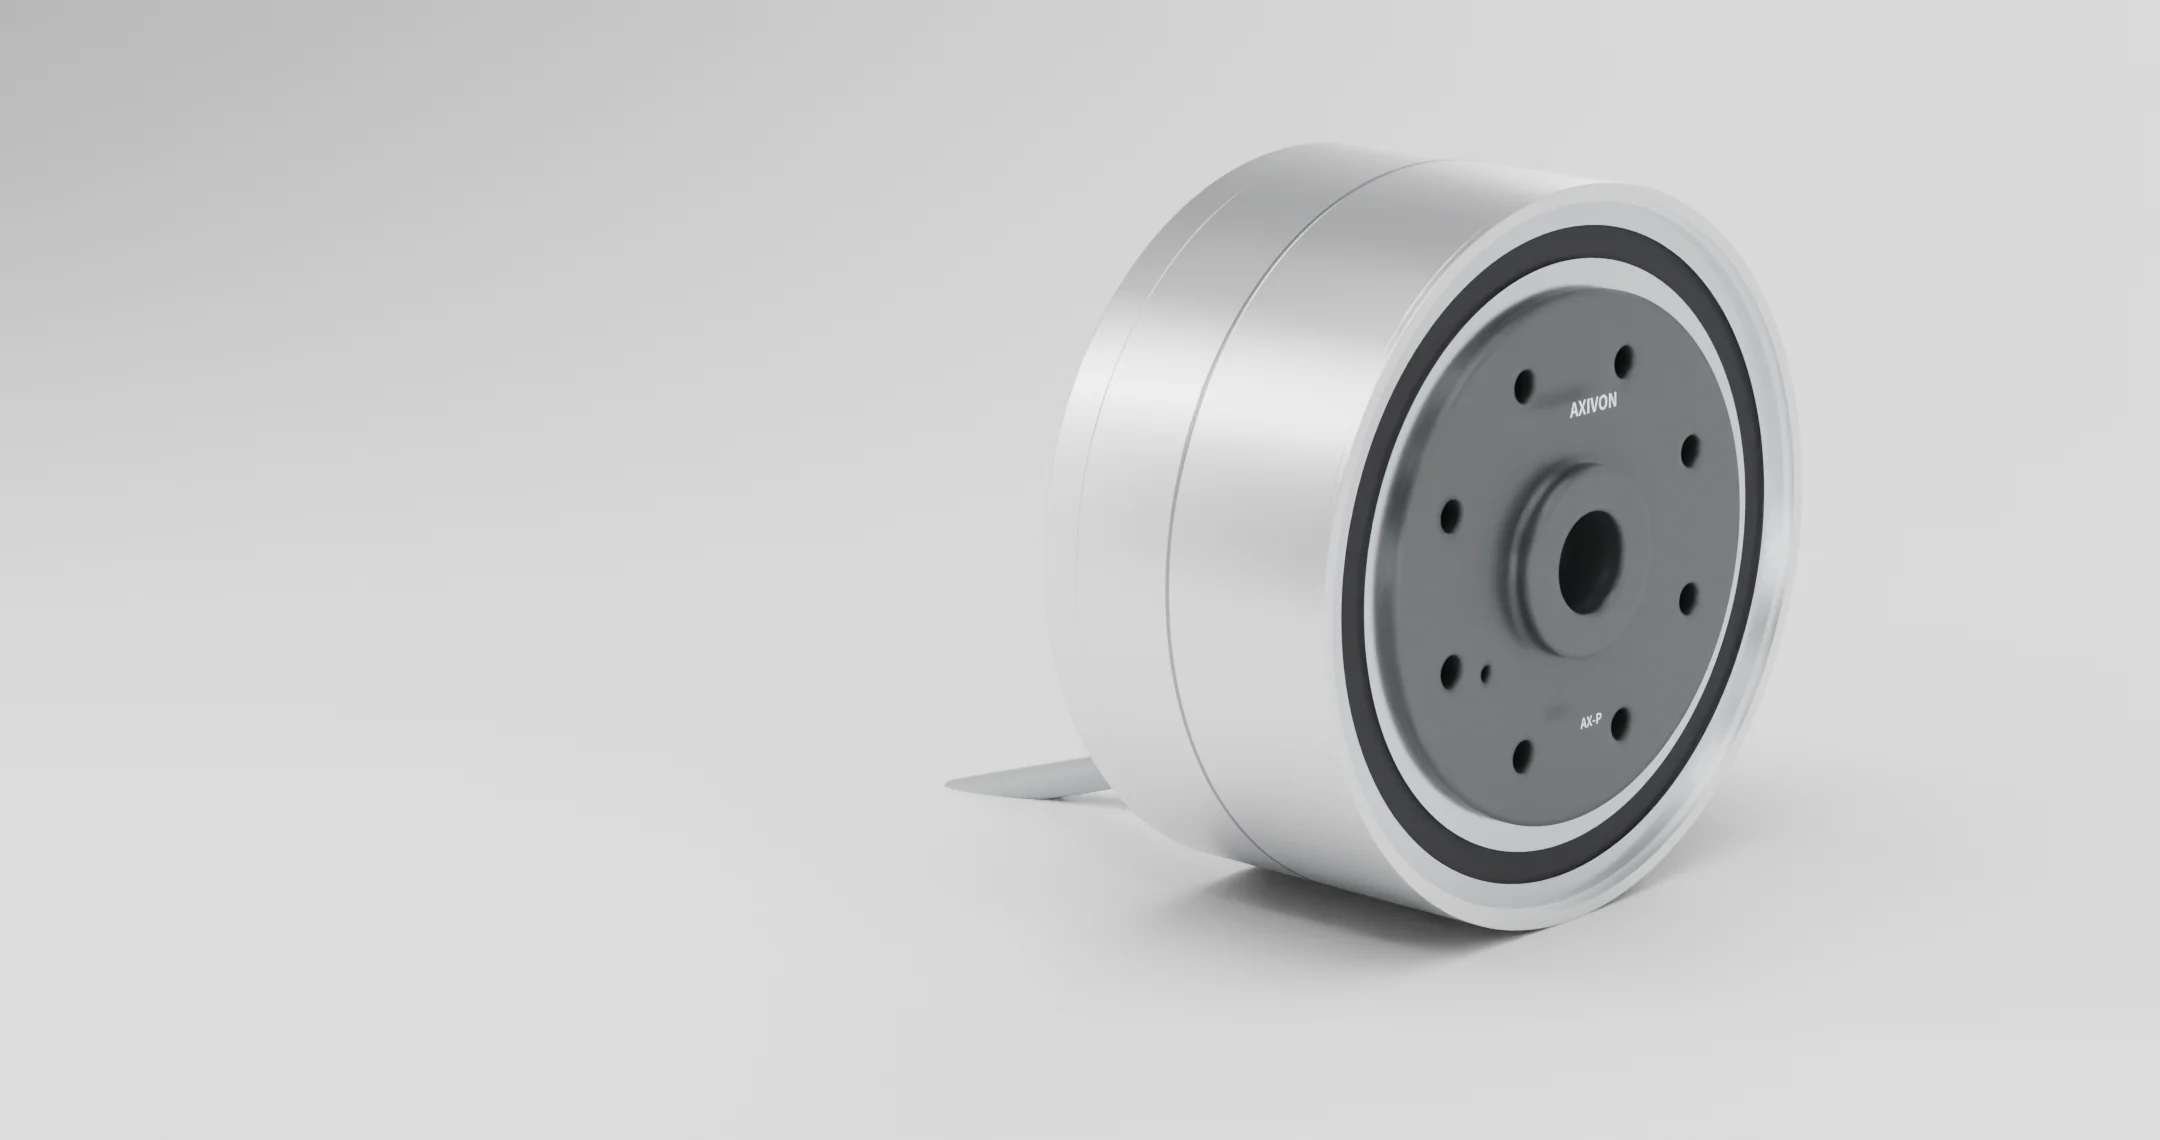
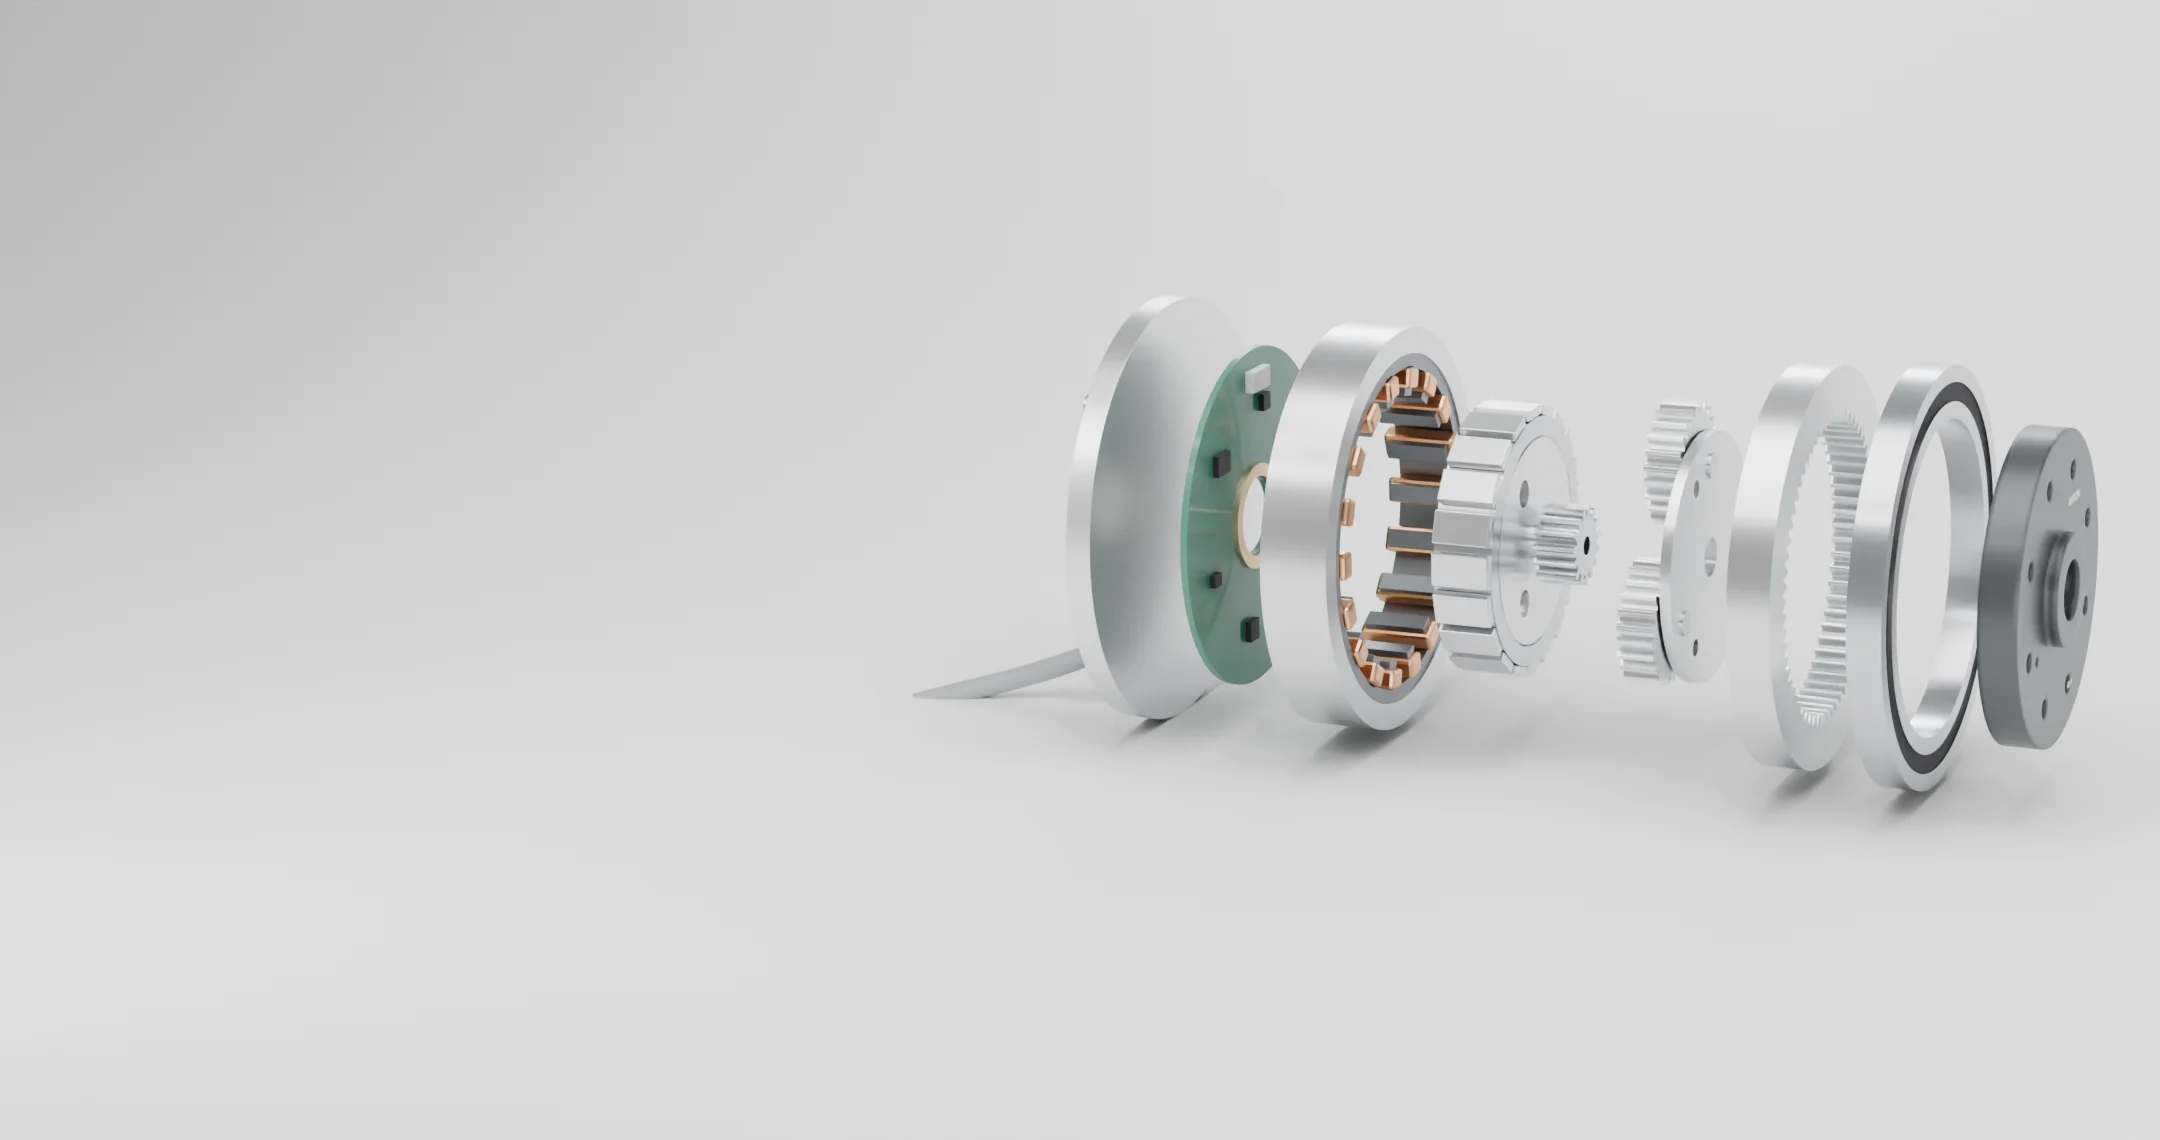
1단 유성기어 감속기입니다. 크기와 감속비는 관절에 맞춰 새로 정하고, 출력부는 크로스 롤러 베어링 하나로 반경·축·모멘트 하중을 받습니다. 상세 사양과 도면은 카탈로그로 보내 드립니다.
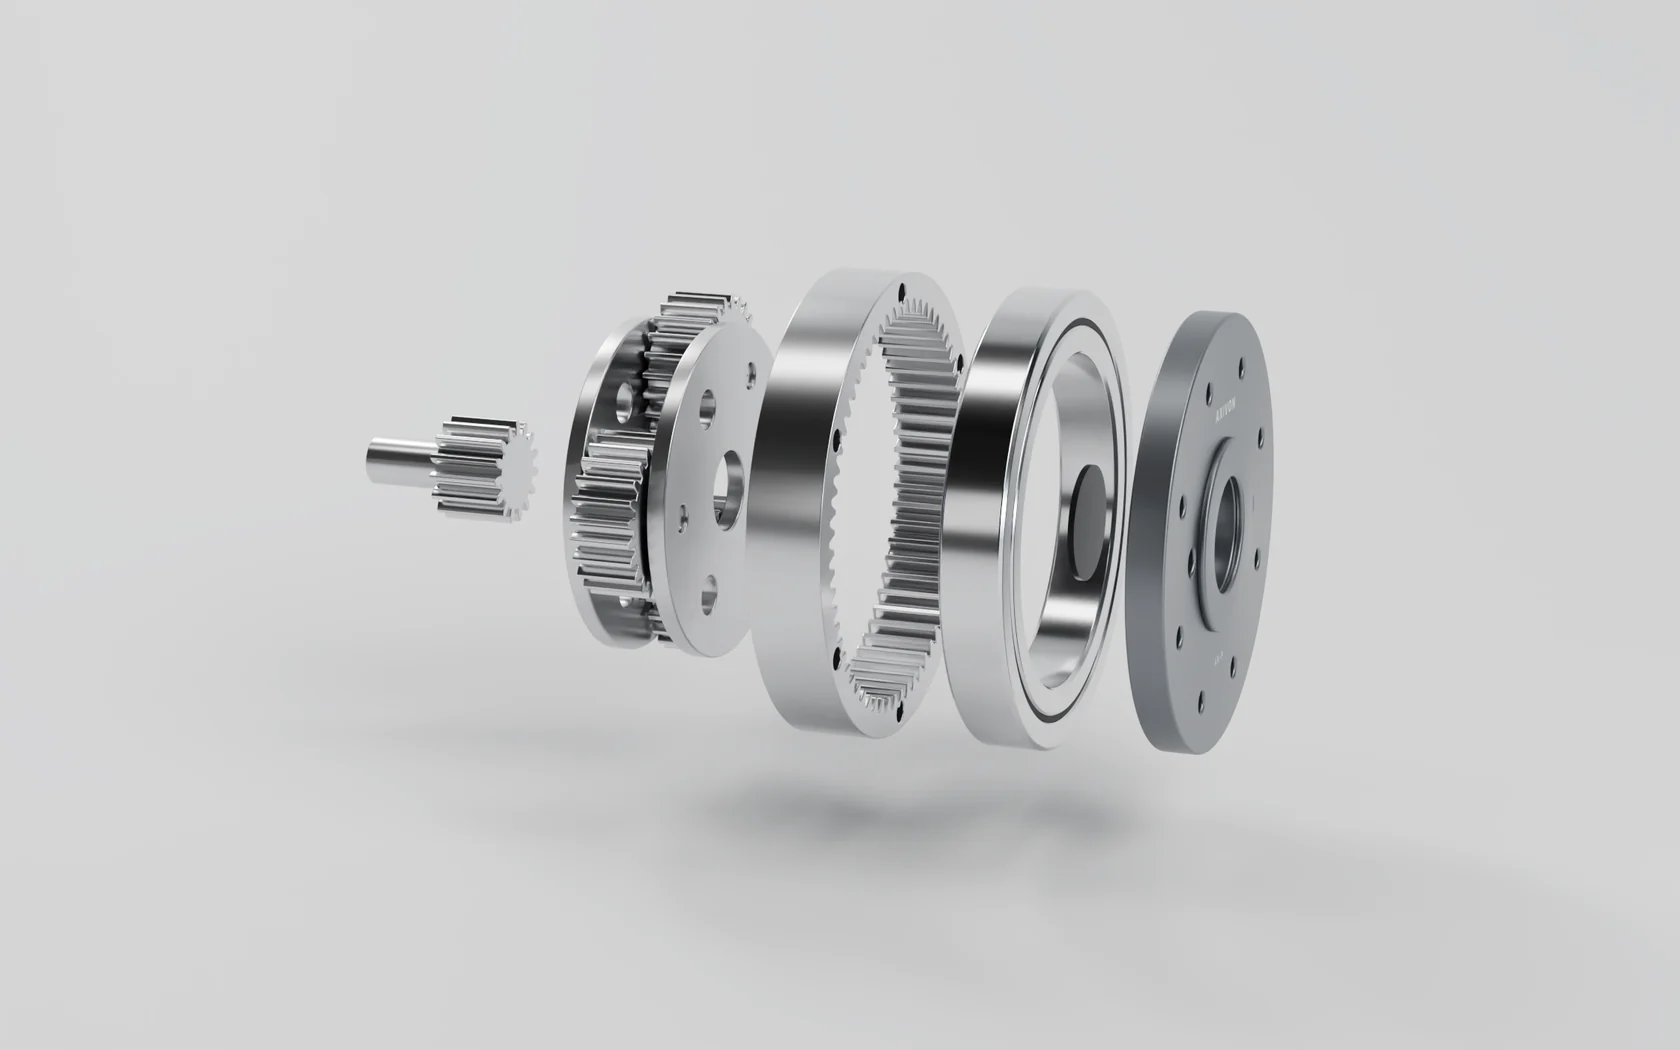
| AX-P 1단 | |
|---|---|
| 감속비 | 5.2 : 1 |
| 구성 | 1단 유성기어, 유성기어 3개 |
| 잇수 | 선기어 15, 유성기어 24, 링기어 63 |
| 출력 베어링 | 크로스 롤러 베어링 |
| 크기 | 로봇별 맞춤 설계 |
| 백래시 · 효율 | 설계 조건으로 산출해 요청 시 제공 |
감속비, 치형, 모터 발열, 베어링과 수명을 관절의 운전 조건으로 계산합니다.
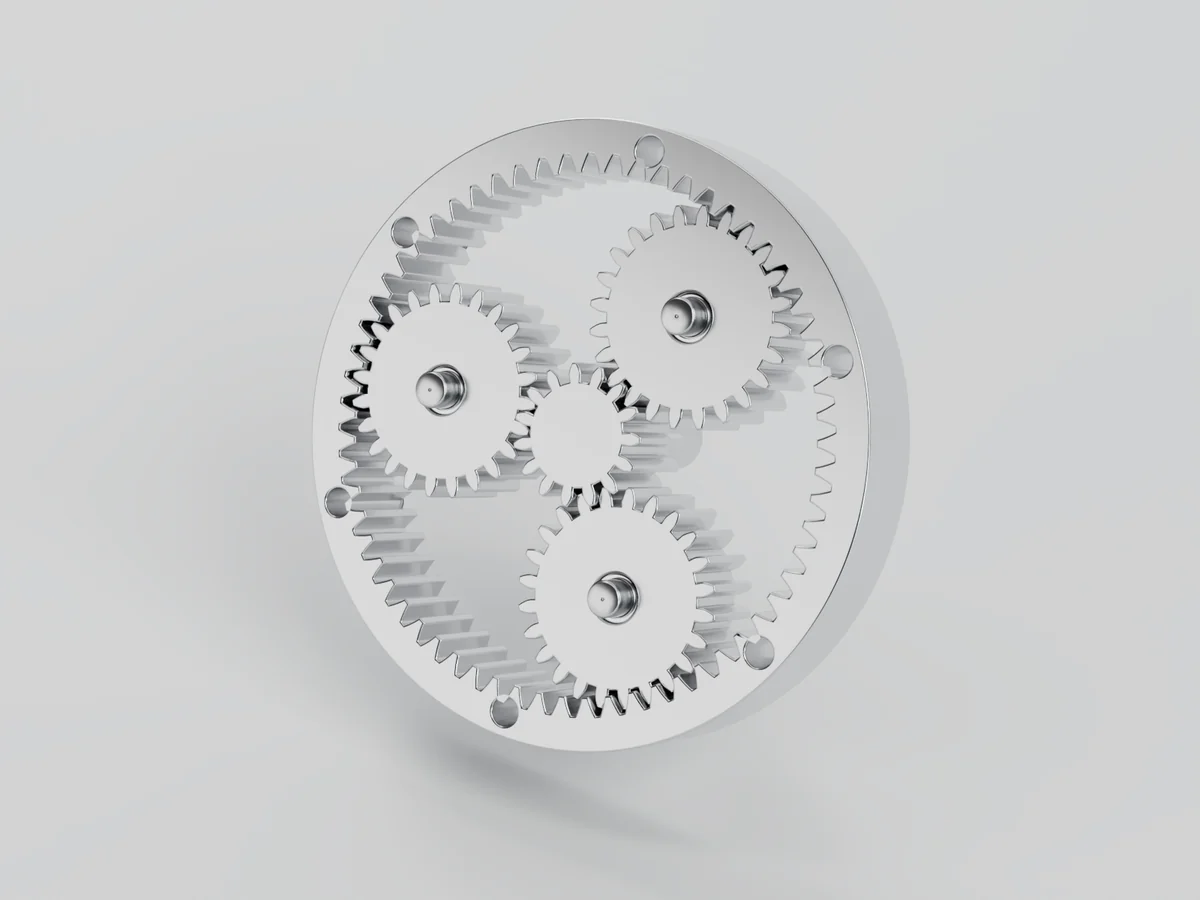
역구동이 쉽고 충격에 강한 범위 안에서, 관절에 맞는 감속비를 고릅니다.
유성기어의 잇수와 치형을 관절 하중에 맞춰 설계합니다.
모터의 전기 특성과 발열을 함께 계산해, 연속 운전 조건에서 온도 한계를 넘지 않는지 확인합니다.
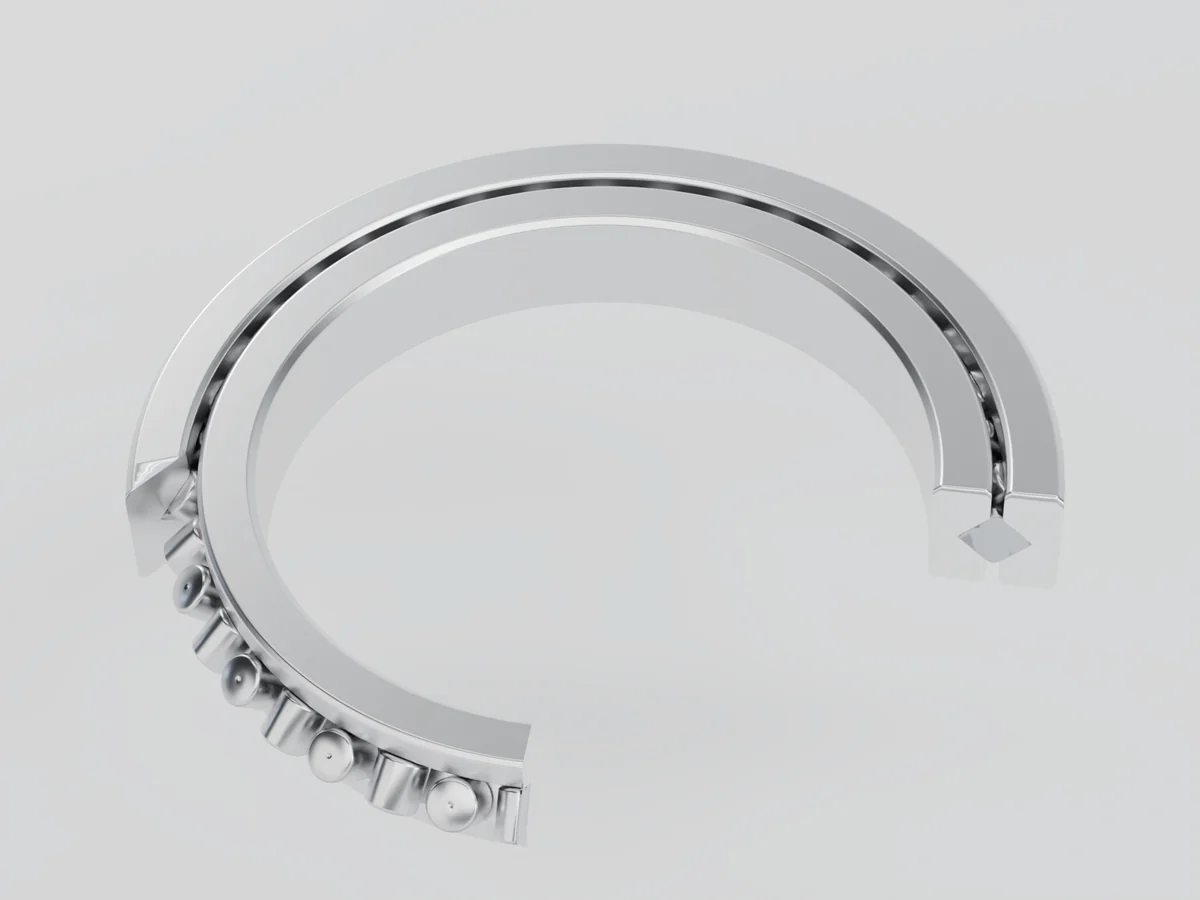
ISO 규격 베어링, DIN 규격 오일실, 크로스 롤러 출력 베어링처럼 구하기 쉬운 표준 부품으로 구성합니다.
방수·방진 등급, 사용 온도, 소음 요구를 설계 단계부터 반영합니다.
실제 운전 패턴으로 기어와 베어링 수명을 계산해 설계에 반영합니다.
같은 감속기라도 관절마다 먼저 따져야 할 조건이 다릅니다. 아래 항목을 알려 주시면 그 관절에 맞춰 설계합니다.
| 관절 | 먼저 따질 조건 | 알려 주실 값 |
|---|---|---|
| 발목 | 착지 충격, 좁은 설치 공간 | 충격 하중, 설치 공간, 움직이는 각도 |
| 무릎 | 앉고 일어설 때의 큰 토크 | 최대·연속 토크, 속도, 운전 시간 |
| 고관절 | 여러 축이 겹치는 공간, 모멘트 하중 | 축 배치, 모멘트 하중, 설치 공간 |
| 손목 | 팔 끝의 무게, 정밀한 위치 | 무게 한도, 백래시 요구, 설치 공간 |
주력 제품입니다. 로봇마다 크기와 감속비를 새로 설계한 AX-P 유성기어 감속기를 공급합니다.
감속기에 모터, 드라이브, 엔코더를 더한 관절 모듈로도 설계합니다. 공급 범위와 일정은 문의해 주시면 안내해 드립니다.
요구 사양을 받으면 자체 AI로 초기 계산을 하고, 시니어 엔지니어가 검토해 설계를 확정합니다.
토크, 속도, 크기, 사용 환경을 알려 주세요. 비어 있는 항목은 함께 정리합니다.
잇수와 감속비 조합을 계산해 비교하고, 엔지니어가 강도, 조립, 원가를 따져 설계를 확정합니다.
운전 조건에서 토크, 발열, 수명을 해석으로 확인한 뒤 견적과 도면을 보내 드립니다.
대기업 자동차 연구소 출신 시니어 엔지니어들이 모든 설계를 검토하고 확정합니다.
RFQ 양식으로 요구 사양을 받은 뒤, 1차 설계와 엔지니어 검토, 가상 시험을 거쳐 견적과 도면을 보내 드립니다.
네. 기존 모터와 드라이브에 맞춰 결합부를 설계한 감속기만 공급할 수 있습니다.
드라이브, 모터, 엔코더 협력사와 통합을 협의하고 있으며, 협력사 선정 후 공급할 예정입니다.
로봇마다 관절의 크기와 하중이 다릅니다. AXIVON은 관절마다 잇수와 크기를 다시 계산해 AX-P 유성기어 감속기를 설계·공급하고, 모터와 드라이브를 더한 액츄에이터 설계도 상담합니다.

1단 유성기어 감속기입니다. 크기와 감속비는 관절에 맞춰 새로 정하고, 출력부는 크로스 롤러 베어링 하나로 반경·축·모멘트 하중을 받습니다. 상세 사양과 도면은 카탈로그로 보내 드립니다.

| AX-P 1단 | |
|---|---|
| 감속비 | 5.2 : 1 |
| 구성 | 1단 유성기어, 유성기어 3개 |
| 잇수 | 선기어 15, 유성기어 24, 링기어 63 |
| 출력 베어링 | 크로스 롤러 베어링 |
| 크기 | 로봇별 맞춤 설계 |
| 백래시 · 효율 | 설계 조건으로 산출해 요청 시 제공 |
감속비, 치형, 모터 발열, 베어링과 수명을 관절의 운전 조건으로 계산합니다.
역구동이 쉽고 충격에 강한 범위 안에서, 관절에 맞는 감속비를 고릅니다.
유성기어의 잇수와 치형을 관절 하중에 맞춰 설계합니다.
모터의 전기 특성과 발열을 함께 계산해, 연속 운전 조건에서 온도 한계를 넘지 않는지 확인합니다.
ISO 규격 베어링, DIN 규격 오일실, 크로스 롤러 출력 베어링처럼 구하기 쉬운 표준 부품으로 구성합니다.
방수·방진 등급, 사용 온도, 소음 요구를 설계 단계부터 반영합니다.
실제 운전 패턴으로 기어와 베어링 수명을 계산해 설계에 반영합니다.
같은 감속기라도 관절마다 먼저 따져야 할 조건이 다릅니다. 아래 항목을 알려 주시면 그 관절에 맞춰 설계합니다.
| 관절 | 먼저 따질 조건 | 알려 주실 값 |
|---|---|---|
| 발목 | 착지 충격, 좁은 설치 공간 | 충격 하중, 설치 공간, 움직이는 각도 |
| 무릎 | 앉고 일어설 때의 큰 토크 | 최대·연속 토크, 속도, 운전 시간 |
| 고관절 | 여러 축이 겹치는 공간, 모멘트 하중 | 축 배치, 모멘트 하중, 설치 공간 |
| 손목 | 팔 끝의 무게, 정밀한 위치 | 무게 한도, 백래시 요구, 설치 공간 |
주력 제품입니다. 로봇마다 크기와 감속비를 새로 설계한 AX-P 유성기어 감속기를 공급합니다.
감속기에 모터, 드라이브, 엔코더를 더한 관절 모듈로도 설계합니다. 공급 범위와 일정은 문의해 주시면 안내해 드립니다.
요구 사양을 받으면 자체 AI로 초기 계산을 하고, 시니어 엔지니어가 검토해 설계를 확정합니다.
토크, 속도, 크기, 사용 환경을 알려 주세요. 비어 있는 항목은 함께 정리합니다.
잇수와 감속비 조합을 계산해 비교하고, 엔지니어가 강도, 조립, 원가를 따져 설계를 확정합니다.
운전 조건에서 토크, 발열, 수명을 해석으로 확인한 뒤 견적과 도면을 보내 드립니다.
대기업 자동차 연구소 출신 시니어 엔지니어들이 모든 설계를 검토하고 확정합니다.
RFQ 양식으로 요구 사양을 받은 뒤, 1차 설계와 엔지니어 검토, 가상 시험을 거쳐 견적과 도면을 보내 드립니다.
네. 기존 모터와 드라이브에 맞춰 결합부를 설계한 감속기만 공급할 수 있습니다.
드라이브, 모터, 엔코더 협력사와 통합을 협의하고 있으며, 협력사 선정 후 공급할 예정입니다.

Every robot joint has its own size and load. AXIVON recalculates tooth counts and size for each joint to design and supply the AX-P planetary reducer, and also advises on actuator design with motor and drive.
A single-stage planetary reducer. Size and ratio are set for each joint, and a single crossed roller bearing carries radial, axial and moment loads at the output. Detailed specifications and drawings come with the catalog.

| AX-P 1-stage | |
|---|---|
| Ratio | 5.2 : 1 |
| Layout | Single-stage planetary, three planets |
| Teeth | Sun 15, planets 24, ring 63 |
| Output bearing | Crossed roller bearing |
| Size | Designed per robot |
| Backlash · efficiency | Calculated for your load case, on request |
Ratio, tooth geometry, motor heat, bearings and service life are calculated against the joint's operating conditions.
Within the low-ratio range that stays backdrivable and absorbs impacts, we pick the ratio each joint needs.
Planetary tooth counts and profiles are designed for each joint load.
Electrical and thermal behavior are calculated together to confirm the motor stays within its temperature limit in continuous duty.
ISO bearings, DIN oil seals and a crossed roller output bearing keep parts easy to source.
Ingress rating, operating temperature and noise limits go into the design from the start.
Gear and bearing life is calculated from the real duty cycle and fed back into the design.
The same reducer faces different demands in each joint. Tell us these inputs and we design for that joint.
| Joint | Key concern | What we need from you |
|---|---|---|
| Ankle | Landing impact, tight space | Impact load, envelope, range of motion |
| Knee | High torque when sitting and standing | Peak and continuous torque, speed, duty time |
| Hip | Stacked axes, moment loads | Axis layout, moment load, envelope |
| Wrist | Mass at the end of the arm, precise positioning | Mass limit, backlash requirement, envelope |
Our core product: AX-P planetary reducers, with size and ratio designed for each robot.
We also design joint modules that add a motor, drive and encoder to our reducer. Ask us about scope and timing.
When your requirements arrive, our in-house AI runs the first calculations and senior engineers review and finalize the design.
Tell us torque, speed, envelope and operating conditions. We work out any gaps with you.
We compare tooth-count and ratio options, and engineers settle strength, assembly and cost before the design is final.
We check torque, heat and life against your operating conditions in simulation, then send the quote and drawings.
Senior engineers from a major automotive research center review and finalize every design.
We take your requirements through the RFQ form, then run a first design, engineer review and virtual test before sending a quote and drawings.
Yes. We can supply the reducer alone, with an interface designed for your existing motor and drive.
We are working with drive, motor and encoder partners and will supply actuators once partners are selected.
Email us and we will send the RFQ form. Leave any values you have not settled yet blank and we will work them out with you.
Every robot joint has its own size and load. AXIVON recalculates tooth counts and size for each joint to design and supply the AX-P planetary reducer, and also advises on actuator design with motor and drive.

A single-stage planetary reducer. Size and ratio are set for each joint, and a single crossed roller bearing carries radial, axial and moment loads at the output. Detailed specifications and drawings come with the catalog.

| AX-P 1-stage | |
|---|---|
| Ratio | 5.2 : 1 |
| Layout | Single-stage planetary, three planets |
| Teeth | Sun 15, planets 24, ring 63 |
| Output bearing | Crossed roller bearing |
| Size | Designed per robot |
| Backlash · efficiency | Calculated for your load case, on request |
Ratio, tooth geometry, motor heat, bearings and service life are calculated against the joint's operating conditions.
Within the low-ratio range that stays backdrivable and absorbs impacts, we pick the ratio each joint needs.
Planetary tooth counts and profiles are designed for each joint load.
Electrical and thermal behavior are calculated together to confirm the motor stays within its temperature limit in continuous duty.
ISO bearings, DIN oil seals and a crossed roller output bearing keep parts easy to source.
Ingress rating, operating temperature and noise limits go into the design from the start.
Gear and bearing life is calculated from the real duty cycle and fed back into the design.
The same reducer faces different demands in each joint. Tell us these inputs and we design for that joint.
| Joint | Key concern | What we need from you |
|---|---|---|
| Ankle | Landing impact, tight space | Impact load, envelope, range of motion |
| Knee | High torque when sitting and standing | Peak and continuous torque, speed, duty time |
| Hip | Stacked axes, moment loads | Axis layout, moment load, envelope |
| Wrist | Mass at the end of the arm, precise positioning | Mass limit, backlash requirement, envelope |
Our core product: AX-P planetary reducers, with size and ratio designed for each robot.
We also design joint modules that add a motor, drive and encoder to our reducer. Ask us about scope and timing.
When your requirements arrive, our in-house AI runs the first calculations and senior engineers review and finalize the design.
Tell us torque, speed, envelope and operating conditions. We work out any gaps with you.
We compare tooth-count and ratio options, and engineers settle strength, assembly and cost before the design is final.
We check torque, heat and life against your operating conditions in simulation, then send the quote and drawings.
Senior engineers from a major automotive research center review and finalize every design.
We take your requirements through the RFQ form, then run a first design, engineer review and virtual test before sending a quote and drawings.
Yes. We can supply the reducer alone, with an interface designed for your existing motor and drive.
We are working with drive, motor and encoder partners and will supply actuators once partners are selected.
Email us and we will send the RFQ form. Leave any values you have not settled yet blank and we will work them out with you.